
RFQ Preparation Checklist
- Axis payload and arm inertia assumptions
- Cycle-time and acceleration profile
- Repeatability target and backlash budget
- Motor model and controller family
Selection and validation guidance for SCARA robot axes requiring high repeatability and controlled backlash.
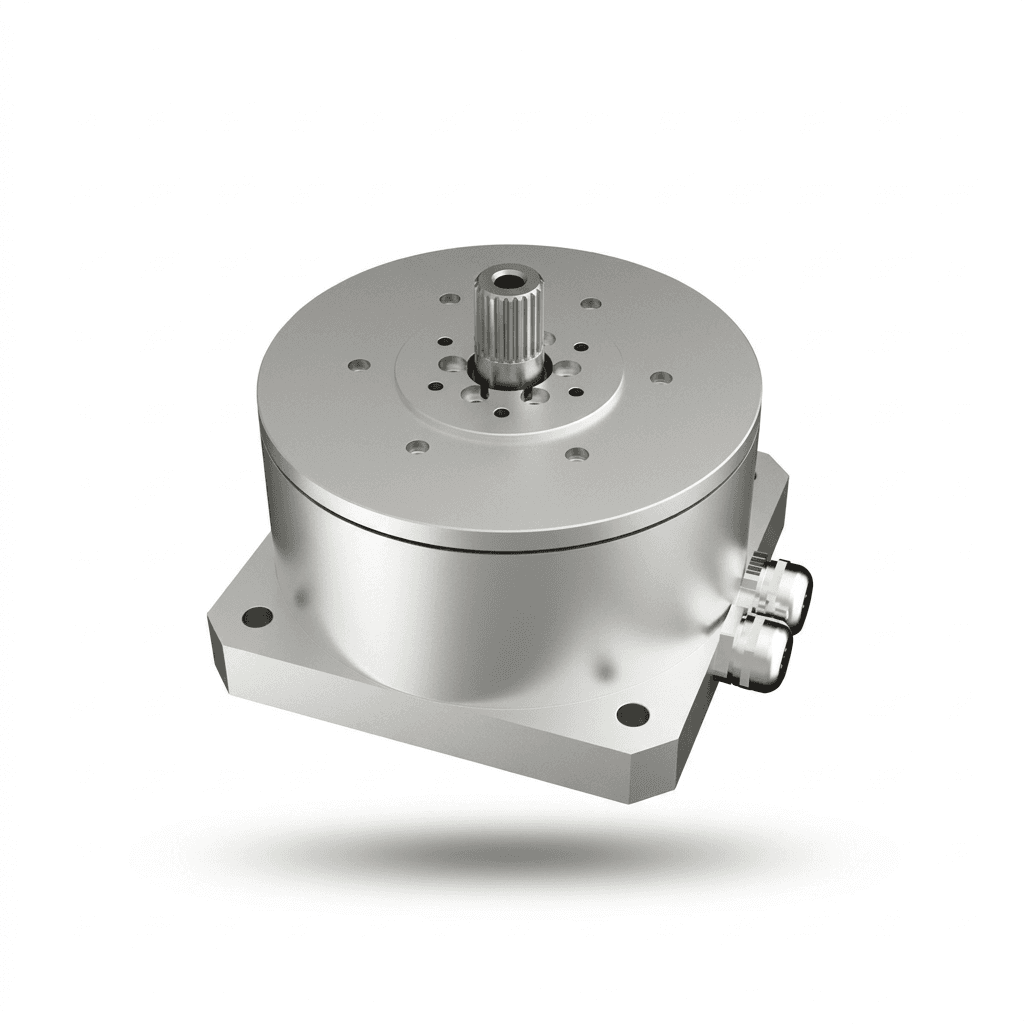
| Evaluation Metric | Typical Range | Buyer Relevance |
|---|---|---|
| Repeatability Target | ±0.02 to ±0.10 mm | Gearhead characteristics directly influence repeatability performance. |
| Inertia Ratio | Recommended <= 5:1 | Improves tuning robustness and reduces oscillation risk. |
This worksheet helps cross-functional teams convert scenario assumptions into measurable evaluation gates before RFQ lock.
| Decision Gate | Why It Matters | Input to Send | Exit Condition |
|---|---|---|---|
| Repeatability Target | Gearhead characteristics directly influence repeatability performance. | Axis payload and arm inertia assumptions | Mitigation agreed: Review inertia matching at full mechanism level, not single component level. |
| Inertia Ratio | Improves tuning robustness and reduces oscillation risk. | Cycle-time and acceleration profile | Mitigation agreed: Review inertia matching at full mechanism level, not single component level. |
Recommended first-thread payload: motion profile, transient peaks, duty cycle, interface revision, and pilot schedule.
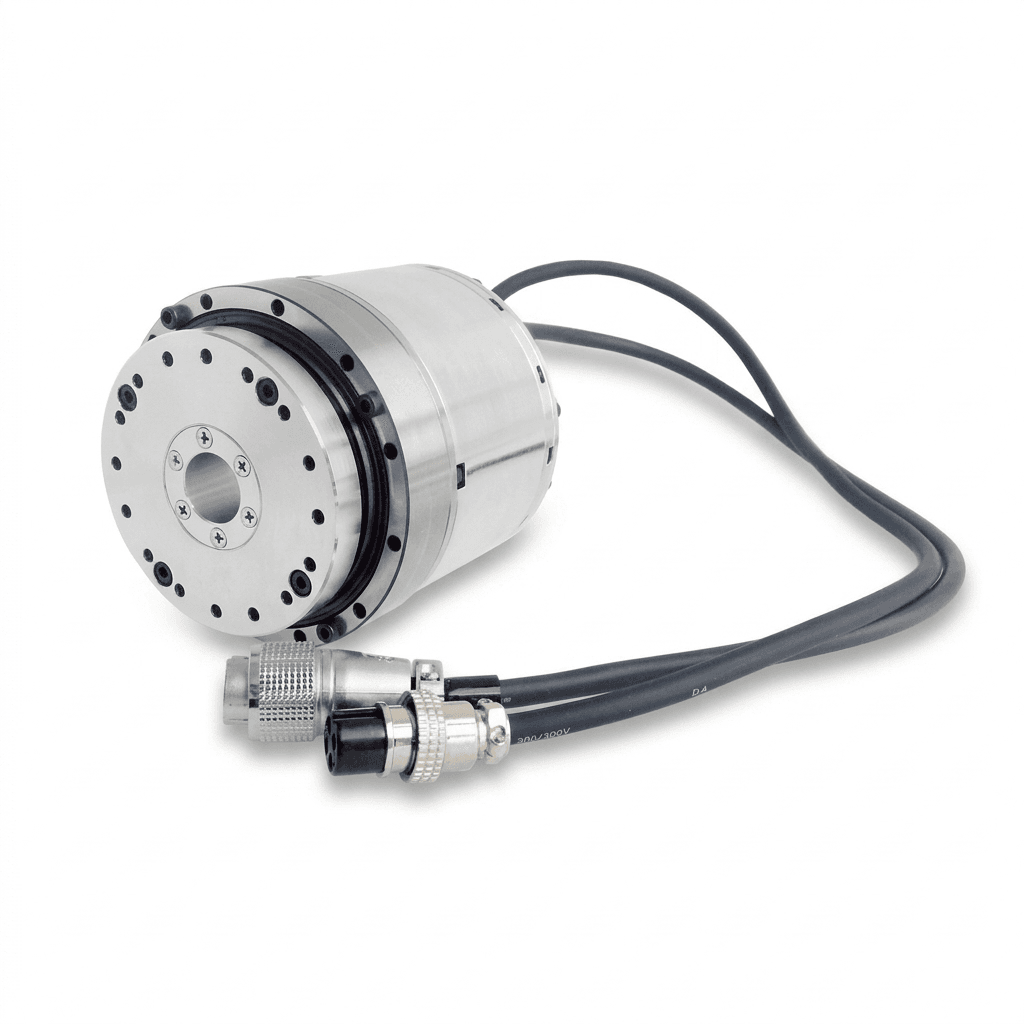
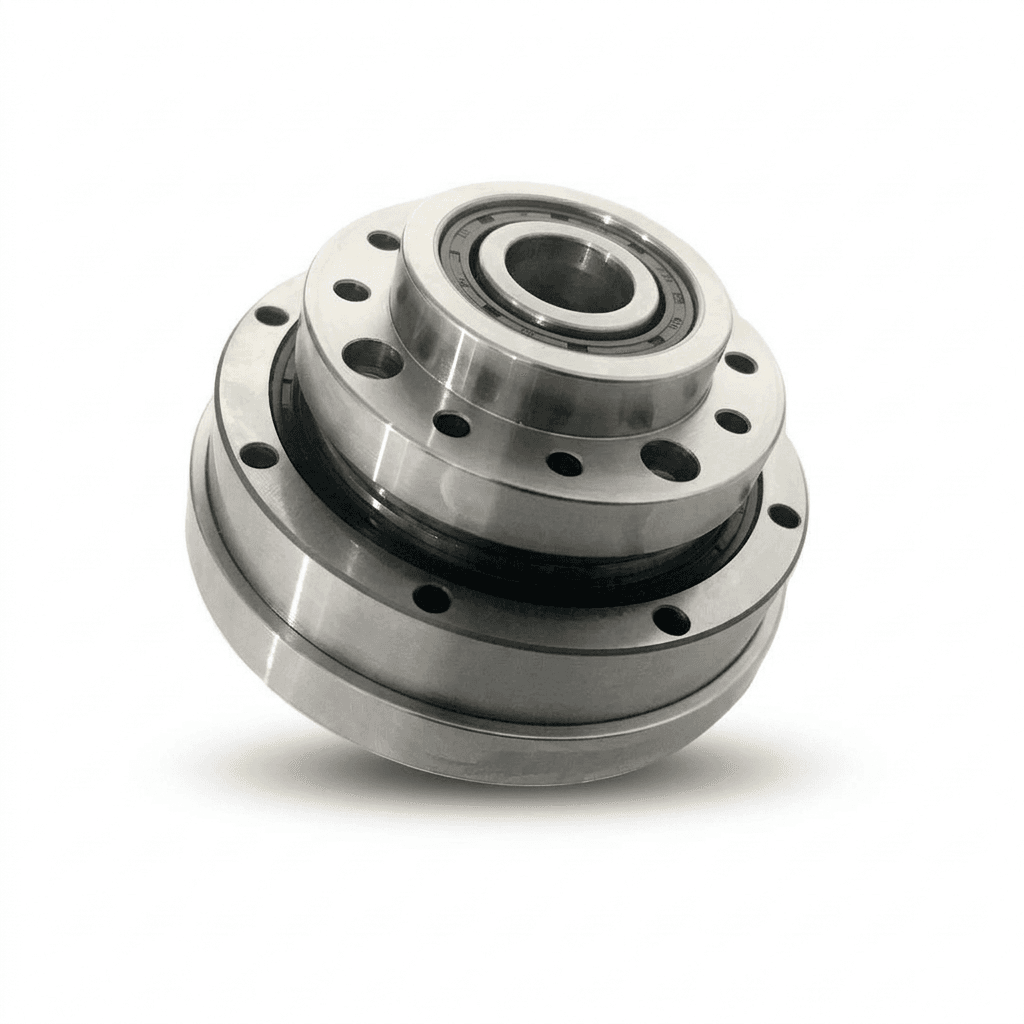
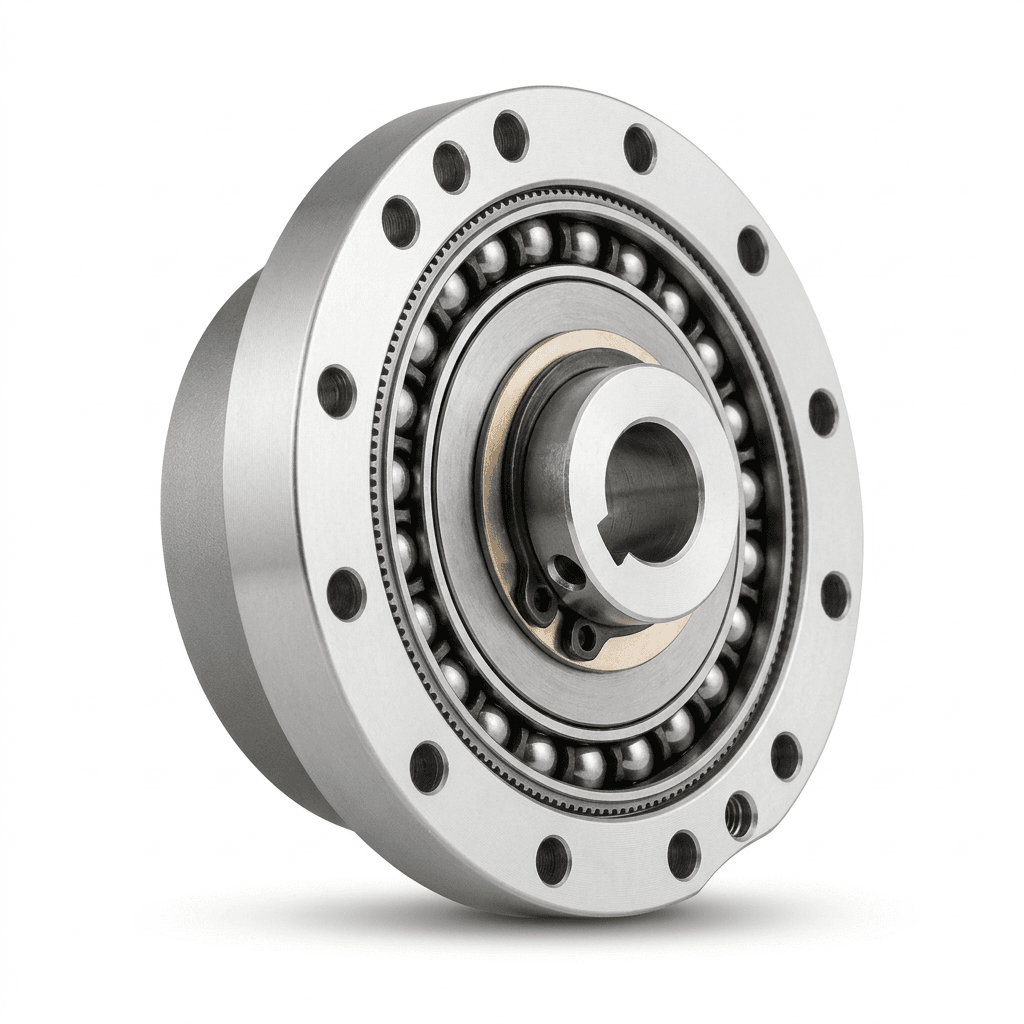
Yes. Early-stage motor and ratio review is supported to reduce redesign loops.
Use these references to turn scenario assumptions into measurable motor-gearhead selection criteria.
Build first-pass ratio boundaries from inertia and torque before vendor comparison.
Pick frame size by actual duty profile, torque reserve, and thermal margin.
Translate technical reliability assumptions into procurement decisions with fewer ramp surprises.
Inquiry Email
Start inquiry opens your default email app.